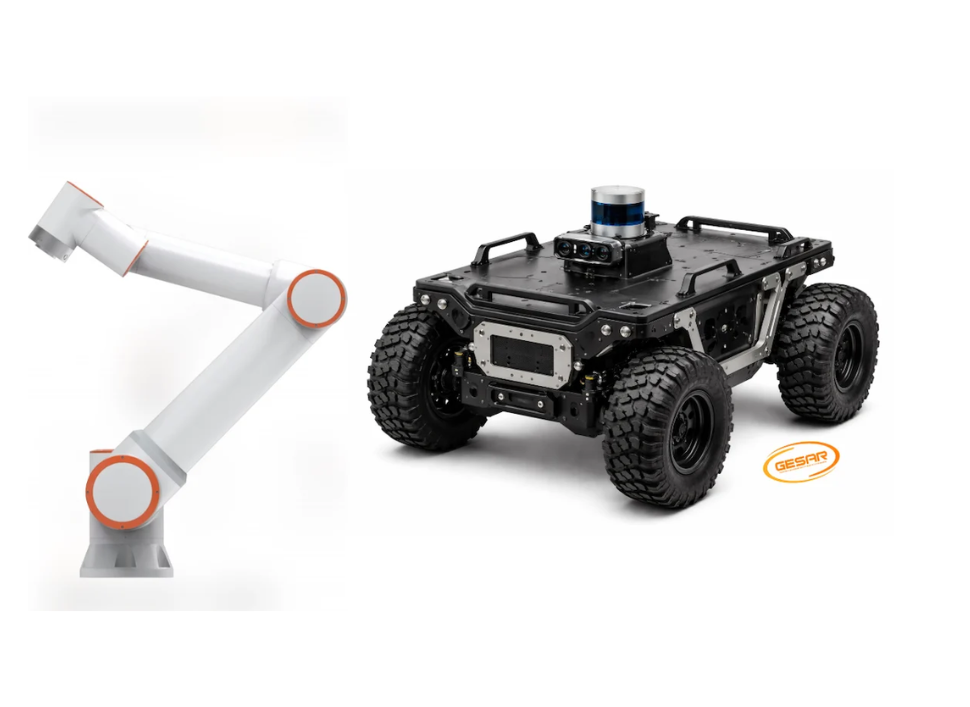
GESAR INC. has developed a line of custom four-wheel Unmanned Ground Vehicle (UGV) chassis designed to host and mobilize Fairino's open-architecture collaborative robots, combining mobile robotic infrastructure with collaborative robotic arms for applications across industrial and hazardous environments.
The robotic system integration specialist has engineered the UGV platform to support operations that require mobility across unstructured, high-risk or outdoor terrain. The system combines Fairino's high-payload, low-latency collaborative arms with rugged, teleoperated mobile infrastructure, allowing operators to perform physical tasks remotely.
ROS 2-Based Platform Supports Mobile Inspection
At the core of the system is GESAR's proprietary four-wheel UGV chassis, which can be configured according to customer requirements for payload capacity, speed limits and operating environments. Its skid-steer, or "tank mode," maneuverability enables operation in confined areas and challenging outdoor terrain.
Each chassis is built natively on a ROS 2 framework, supporting unified data pipelines across the mobile platform and robotic systems. Fairino cobots can be integrated with the UGV's onboard computing architecture through their open-source SDKs and API-driven motion control.
According to GESAR, the resulting platform supports sub-millisecond real-time coordinate handoffs, 2D and 3D LiDAR mapping, and adaptive simultaneous localization and mapping (SLAM) under severe communication constraints or in GPS-denied environments.
UGV Platform Supports NDT and Inspection Applications
For the NDT and inspection sector, the mobile platform is designed for use in hazardous oil, gas and energy infrastructure environments.
The UGV can traverse rough terrain while positioning Fairino robotic arms equipped with ultrasonic, eddy-current or thermal NDT sensors against critical structural components with millimeter precision.
This configuration combines mobile ground-based access with robotic sensor positioning for inspection tasks in environments where remote operation is required.
Applications Across Industrial Environments
Beyond NDT and inspection, GESAR's platform is intended for several applications.
In industrial logistics and facility operations, the mobile manipulators can navigate warehouses while Fairino arms manipulate industrial valves, open heavy containment doors and sort materials on dynamic facility floors.
For precision agriculture, the four-wheel chassis is designed for muddy and uneven row-crop fields, while the integrated cobot can perform tasks such as autonomous pruning, selective harvesting and targeted crop-health sampling.
In construction and remote material handling, operators can use low-latency teleoperation to command the UGV and robotic arm to handle materials, deploy field sensors or assist with heavy-machinery setups from a remote command station.
Virtual Validation Before Manufacturing
GESAR also provides virtual validation before physical components are manufactured. Using Fairino's official 3D digital assets, the company develops simulation layouts based on a customer's application description, target payload weights and operating terrain.
The mobile platform can be configured with systems ranging from lightweight inspection arms to heavy-duty variants capable of handling 30 kg payloads, allowing the UGV configuration to be matched to different operational requirements.